Curvilinear motion describes a particle travelling along a curved path in space rather than a straight line, as seen in rectilinear motion. Unlike rotation about a fixed axis, there is no rigid body and no stationary axis.
Even with a constant speed, the direction of the velocity vector is constantly changing, which means acceleration is always present.
Coordinate Systems
Curvilinear motion can be described in a number of coordinate systems depending on how the path is described or constrained. A coordinate system can be chosen in order to simplify a problem.
Vector Definitions
Curvilinear motion is described using vectors as we need to account for the magnitude and direction of curved motion.
| Kinematic Quantity | Vector Notation | Derivative Definition |
|---|---|---|
| Position | — | |
| Velocity | ||
| Acceleration |
The magnitude of velocity (speed) is given by:
Rectangular Coordinates ()
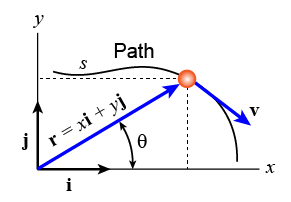
Rectangular coordinates (also known as cartesian coordinates) are best used when paths are independent along perpendicular axes. Motion can be split into directions and be treated as 1D in each respective axis.
Quote bq
The reference axes do not change direction over time.
Unit vectors () are constant in magnitude and direction.
Each kinematic quantity is split into components for each direction.
Normal & Tangential Coordinates ()
Normal and tangential coordinates are best used when the physical path of motion is known. Motion is split into normal & tangential components.
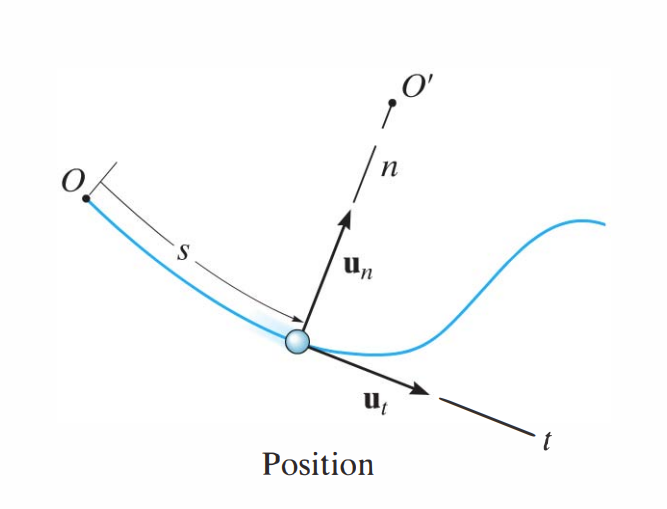
The unit vectors () move with the particle. points towards the centre of curvature () and is tangent to the path. The reference frame constantly moves and rotates with the particle.
Radius of Curvature
The centre of curvature () is an imaginary point that lies on the concave side of the curve. The -axis has positive direction towards
The radius of curvature () is perpendicular distance from curve to .
An advantage of this coordinate system is that it isolates speed changes from the change in direction of the path. is known as tangential acceleration and is known as centripetal acceleration.
| Parameter | Formula | Description |
|---|---|---|
| Position (scalar) | Distance along the curve from a fixed reference point. | |
| Velocity Vector | Tangent to path, no normal velocity. | |
| Total Acceleration | Combined vector tracking changes in both speed and path direction. | |
| Tangential Acceleration | Parallel to travel; purely responsible for changing the object’s speed. | |
| Normal Acceleration | Perpendicular to travel; purely responsible for changing direction. |
Path Angle
The path angle () is the angle the tangent vector makes with a fixed horizontal axis. Its time-derivative () represents the angular velocity of the velocity vector (how fast the particle is turning).
Particle’s speed along a curve is directly proportional to how sharply the curve bends () and how fast its direction changes ().
Normal acceleration can also be written in terms of the path angle:
Path angle formulas are useful for when we need to link path geometry and/or angular rotation to acceleration.
Special Cases of Motion
- Particle moves along a straight line
- Particle moves with constant speed along curve
- Tangential acceleration () is constant
- Particle moves along path
Three-Dimensional Normal & Tangential Motion
In 2D, the normal and tangential axes lie together in what is known as the osculating plane. When modelling curvilinear motion of a particle in 3D, we use a binormal axis () to represent the third dimension.
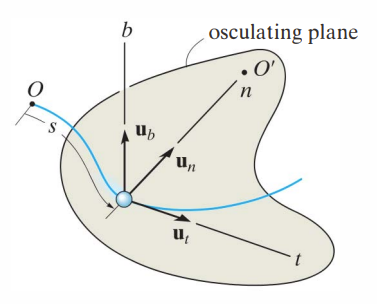
The binormal axis is perpendicular to the osculating plane. Its unit vector is given by the cross product of the other two unit vectors:
There is no motion, velocity or acceleration in the binormal axis as the reference frame will instead rotate to account for change in direction.
Polar & Cylindrical Coordinates ()
Polar coordinates (2D) and cylindrical coordinates (3D) are best used when the motion of a particle is tracked from a central fixed point (origin/pole) rather than along its own path.
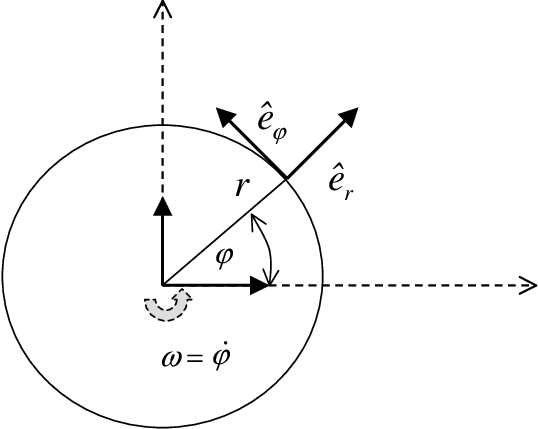
The unit vectors for polar and cylindrical coordinates are attached to the particle. points radially outward from to the particle. is perpendicular to in the direction of increasing . As these terms rotate with the particle, differentiation produces additional terms for acceleration.
Unit Vector Notation
Traditionally, is used for the notation of unit vectors. However, you will find most notation in this vault will use instead, with for unit.
| Parameter | Formula | Description |
|---|---|---|
| Radius | Distance from to particle. | |
| Radial Velocity | Rate of motion towards/away from . | |
| Transverse Velocity | Rate of motion to , due to rotation. | |
| Radial Acceleration | Linear + centripetal acceleration. | |
| Transverse Acceleration | Tangential + Coriolis term. |
Combining components above, we get total velocity and acceleration:
Special Cases -- Fixed Axis Rotation
If is constant -> .
Equations simplify :
Polar coordinates are a more general representation that reduces to fixed axis rotation when stops changing.
Cylindrical Coordinates (3D)
Cylindrical coordinates are an expansion of polar coordinates into 3D by adding a -axis. The -axis is treated the same way as rectangular , meaning it is independent and non-rotation.
await dv.view("Scripts/topic-backlinks");